
taehyun-byun@korea.ac.kr
Ph.D Student, Dept. of Artificial Intelligence
Korea University
I’m a Ph.D. student in Artificial Intelligence at Korea University, working with Professor Sungjoon Choi in the Robot Intelligence Lab. (RILAB).
My doctoral research, Toward Human-Grounded Humanoid Motion Synthesis, connects generative modeling of human motion with controllable, human-like behaviors for humanoid robots.
I received my M.S. in Statistics from Korea University in Seoul, advised by Professor Myoungshic Jhun, and my B.S. in Information and Mathematics from Korea University in Sejong.
Research Interests
I study generative models, including diffusion and flow matching, to learn human motion distributions and build controllable motion priors. Through motion synthesis and retargeting, I aim to translate these priors into natural movements that fit the embodiment and physical constraints of humanoid robots. I am also interested in human–robot interaction and in developing friendly, natural robot behaviors for everyday settings, including the home.
News
| 2026 |  Our paper “Effective Evaluation of Exoskeleton Using Exo-Agnostic Uncertainty-Aware Classification Model with Wearable Sensors” has been accepted to ACM Augmented Humans (AHs) 2026 as a Poster! |
|---|---|
| 2026 | Our paper “Adaptive Hilbert Diffusion Models for Controllable Smoothness in Continuous Function Generation” has been accepted to Computational Visual Media! Check out the project page. |
| 2026 | Our paper “CLIP-Actor-X” has been accepted to IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI)! |
Publications
- arXiv
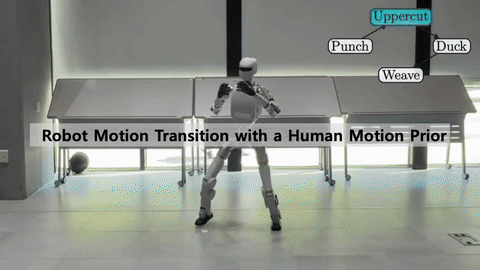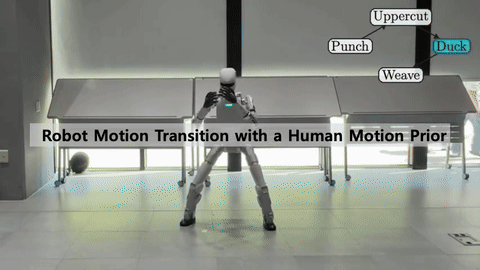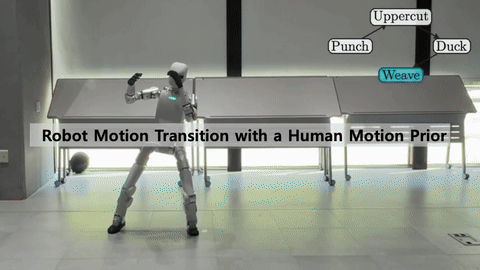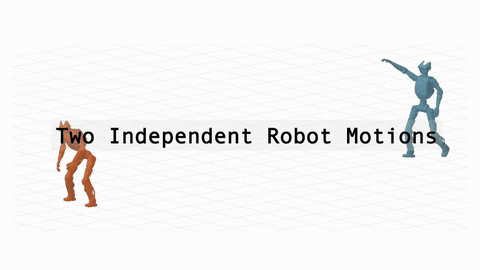
- PR
 Controllable Single Motion SynthesisPattern Recognition (IF: 7.6, 2024), 2026Revised and resubmitted
- CVM
 Adaptive Hilbert Diffusion Models for Controllable Smoothness in Continuous Function Generation* Equal contribution (co-first authors)Computational Visual Media (IF: 18.3, 2024), 2026Accepted
- TPAMI
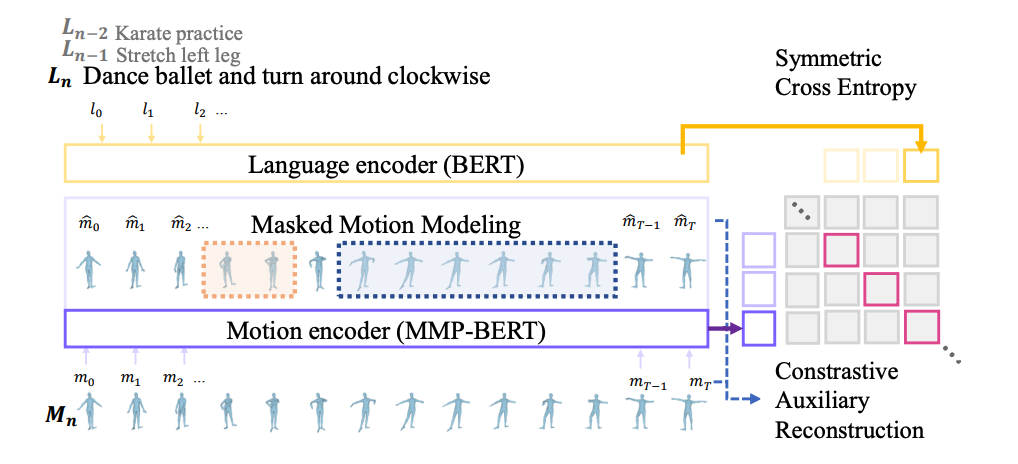
 CLIP-Actor-X: Text-driven 4D Human Avatar Generation via Cross-modal Synthesis-through-Optimization* Equal contribution (co-first authors)IEEE Transactions on Pattern Analysis and Machine Intelligence (IF: 18.6, 2024), 2026
- AHs
 Effective Evaluation of Exoskeleton Using Exo-Agnostic Uncertainty-Aware Classification Model with Wearable SensorsACM Augmented Humans (AHs), 2026Poster
- IROS
 Robust and Expressive Humanoid Motion Retargeting via Optimization-Based Rig UnificationIn 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
- RA-L
 Towards Embedding Dynamic Personas in Interactive Robots: Masquerading Animated Social Kinematic (MASK)IEEE Robotics and Automation Letters (IF: 4.6, 2024), 2024
- NeurIPS
 Score-based generative modeling through stochastic evolution equations in hilbert spacesAdvances in Neural Information Processing Systems, 2023
- arXiv
- PR

-